Ronco RM28-LE
| Model | RM28-LE |
| Vendor | Ronco |
| Description | Zigbee roller shade motor |
| Exposes | cover (state, position), slow_mode, motor_direction, auto_power, motor_state, countdown, countdown_left, time_total, situation_set, motor_fault, battery, cover_limit, favorite_position, click_control |
| Picture | 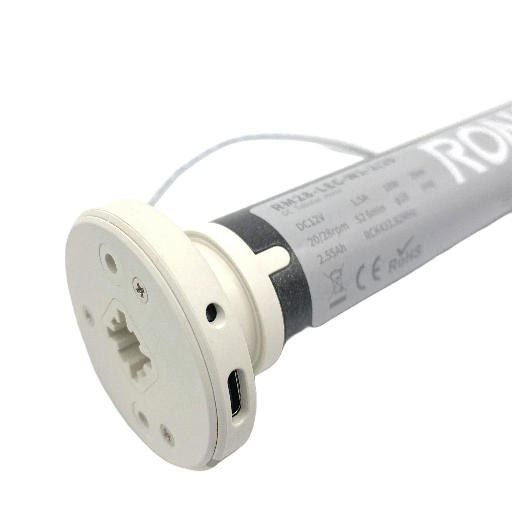 |
Notes
Pairing
- Click the button on the motor 3 times to add or remove from zigbee network.
- The device will enter pairing mode (LED blinks orange).
- When device is paired, led will turn solid green, then turn off.
Factory Rest
- Long press motor button for 12 seconds, motor jogbs 3 times restoring to factory settings.
Options
How to use device type specific configuration
invert_cover: Inverts the reported cover position and the state derived from it, false: open=100,close=0, true: open=0,close=100 (default false). The value must betrueorfalsetime_start: Reply to Tuya-specific time synchronization requests: "1970" - Reply with seconds since 1970/01/01 (recommended, should stop the device from asking), "2000" - Reply with seconds since 2000/01/01 (use if the weekday is wrong with 1970), "off" - Don't reply (use if replying causes too much traffic). Default for this device: "off". The value must be one of1970,2000,off
Exposes
Cover
The current state of this cover is in the published state under the state property (value is OPEN or CLOSE). To control this cover publish a message to topic zigbee2mqtt/FRIENDLY_NAME/set with payload {"state": "OPEN"}, {"state": "CLOSE"}, {"state": "STOP"}. It's not possible to read (/get) this value. To change the position publish a message to topic zigbee2mqtt/FRIENDLY_NAME/set with payload {"position": VALUE} where VALUE is a number between 0 and 100.
Slow mode (binary)
Operate the motor slower and quieter than normal. Value can be found in the published state on the slow_mode property. It's not possible to read (/get) this value. To write (/set) a value publish a message to topic zigbee2mqtt/FRIENDLY_NAME/set with payload {"slow_mode": NEW_VALUE}. If value equals ON slow mode is ON, if OFF OFF.
Motor direction (enum)
Motor rotation direction. Value can be found in the published state on the motor_direction property. It's not possible to read (/get) this value. To write (/set) a value publish a message to topic zigbee2mqtt/FRIENDLY_NAME/set with payload {"motor_direction": NEW_VALUE}. The possible values are: normal, reversed.
Auto power (binary)
Auto-complete open/close when curtain is manually pulled. Value can be found in the published state on the auto_power property. It's not possible to read (/get) this value. To write (/set) a value publish a message to topic zigbee2mqtt/FRIENDLY_NAME/set with payload {"auto_power": NEW_VALUE}. If value equals true auto power is ON, if false OFF.
Motor state (enum)
Current motor movement status. Value can be found in the published state on the motor_state property. It's not possible to read (/get) or write (/set) this value. The possible values are: opening, closing, stopped.
Countdown (enum)
Countdown timer to trigger open/close. Value can be found in the published state on the countdown property. It's not possible to read (/get) this value. To write (/set) a value publish a message to topic zigbee2mqtt/FRIENDLY_NAME/set with payload {"countdown": NEW_VALUE}. The possible values are: cancel, 1h, 2h, 3h, 4h.
Countdown left (numeric)
Remaining countdown time in seconds. Value can be found in the published state on the countdown_left property. It's not possible to read (/get) or write (/set) this value. The unit of this value is s.
Time total (numeric)
Full travel time in ms, populated after calibration. Value can be found in the published state on the time_total property. It's not possible to read (/get) or write (/set) this value. The unit of this value is ms.
Situation set (enum)
Whether motor treats 100% as fully open or fully closed. Value can be found in the published state on the situation_set property. It's not possible to read (/get) or write (/set) this value. The possible values are: fully_open, fully_close.
Motor fault (binary)
Motor hardware fault. Value can be found in the published state on the motor_fault property. It's not possible to read (/get) or write (/set) this value. If value equals true motor fault is ON, if false OFF.
Battery (numeric)
Remaining battery in %, can take up to 24 hours before reported. Value can be found in the published state on the battery property. It's not possible to read (/get) or write (/set) this value. The minimal value is 0 and the maximum value is 100. The unit of this value is %.
Cover limit (enum)
Set current position as the limit position. Value can be found in the published state on the cover_limit property. It's not possible to read (/get) this value. To write (/set) a value publish a message to topic zigbee2mqtt/FRIENDLY_NAME/set with payload {"cover_limit": NEW_VALUE}. The possible values are: set_up, set_down, delete_up, delete_down, delete_both.
Favorite position (numeric)
Store the preferred cover position. Value can be found in the published state on the favorite_position property. It's not possible to read (/get) this value. To write (/set) a value publish a message to topic zigbee2mqtt/FRIENDLY_NAME/set with payload {"favorite_position": NEW_VALUE}. The minimal value is 0 and the maximum value is 100. The unit of this value is %.
Click control (enum)
Step control. Value can be found in the published state on the click_control property. It's not possible to read (/get) this value. To write (/set) a value publish a message to topic zigbee2mqtt/FRIENDLY_NAME/set with payload {"click_control": NEW_VALUE}. The possible values are: up, down.